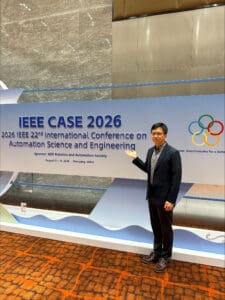
As part of the IEEE CASE 2026 Science Communication Ambassador initiative, Dr. Chin-Yi Lin spoke with Dr. Chia-Yen Lee, Senior Editor, IEEE Transactions on Automation Science and Engineering (T-ASE), about his research presented at CASE 2026, his perspective on important future directions in robotics and automation, and his advice for young researchers entering the field.
From Noisy Images to Smarter Semiconductor Inspection
At CASE 2026, Dr. Lee, collaborating with Tsung-Ta Hsieh, Yu-Hsin Hung, Po-Cheng Shen, and Taho Yang, presented the work:
“Unpaired Image Denoising and Fusion with Adaptive Multi-Branch Task UNet for Semiconductor Packaging Defect Recognition,” published in IEEE Transactions on Automation Science and Engineering.
The study proposes a self-supervised learning framework named MBT (Multi-Branch-Task)-UNet, specifically designed for the denoising and defect recognition of ultrasonic images in semiconductor packaging inspection.
What does denoising mean? Dr. Lee uses a simple analogy: imagine driving in the rain, with raindrops landing on the windshield, and then taking a photo. Those raindrops appear in the picture. The goal of denoising is to remove this type of visual interference while preserving important shapes and edges.
In advanced semiconductor packaging, particularly panel-level packaging, Non-Destructive Testing (NDT) using Scanning Acoustic Microscopy (SAM) is crucial for detecting internal defects. However, inspections are conducted post-molding but before surface grinding. Because the Epoxy Molding Compound (EMC) surface has not been polished, its roughness causes severe ultrasound scattering and noise interference, creating highly noisy C-scan images.
Using a U-Net backbone coupled with multi-branch decoders, the proposed model simultaneously handles noise suppression, image reconstruction, and defect enhancement without requiring paired training data. In other words, the method does not require each noisy defect image to have a corresponding clean, defect-free image.
This is important in practice because sampling inspection is commonly applied, making paired images difficult to identify. Based on training data that include noisy defect images, unpaired clean images, and binary defect masks, the proposed model generates a noise map and a clean map, then reconstructs the noisy defect image by integrating image fusion technology and the Non-Subsampled Contourlet Transform (NSCT) to improve detection accuracy.
Experimental results demonstrate strong performance on Feature Similarity (FSIM) and Learned Perceptual Image Patch Similarity (LPIPS). MBT-UNet achieves competitive performance that closely approximates fully supervised learning models despite being trained entirely on unpaired data. The technology therefore provides a smart manufacturing solution with practical stability and high performance for automated quality inspection in advanced packaging.
Looking Ahead: Important Directions for Robotics and Automation
The consumer technology landscape is moving toward embodied intelligence – integrating virtual software and physical hardware that interact with the real world. While autonomous vehicles, embodied AI/humanoid robots, and home robots share foundational data-driven technologies such as computer vision, multimodal vision-language-action, and spatial mapping, they operate under vastly different physical constraints, behavior models, and safety thresholds.
Drawing on his expertise in manufacturing data science, Dr. Lee identifies three key research directions and open challenges aligned with the scope of IEEE RAS.
- Small Data Problem in Advanced Hardware
For emerging product categories such as embodied AI humanoids, physical production volumes remain low. Consequently, physical interactions and test cycles are too sparse to generate large volumes of data, creating a “small data” problem.
Traditional data science and machine learning models rely on historical failure data to predict line yield or component reliability. Dr. Lee points to Physics-Informed Neural Networks (PINNs) and physics-guided synthetic data generation as ways to bridge this gap. For example, combining physical kinematic equations with empirical manufacturing metrics can help overcome the scarcity of empirical failure logs.
- Dynamic Adaptation in High-Dimensional and Heterogeneous Sensor Fusion
Modern autonomous vehicles and humanoid robots combine optical cameras, sensors, tactile arrays, inertial measurement units, strain gauges, and other sensing systems. Analyzing quality metrics across hundreds of asynchronous time-series sensors during end-of-line testing creates dimensionality bottlenecks because of spatio-temporal asynchrony and variable sampling rates.
Dr. Lee highlights dynamic latent-space modeling and continuous-time temporal alignment as approaches that can reduce multi-sensor streams into low-dimensional latent spaces while preserving critical performance characteristics. Adaptive Multivariate Statistical Process Control (AMSPC) could then help characterize interactions among multiple sensors, update control limits dynamically, and enhance production quality.
- Sim-to-Real and Digital Twin Calibration Loops
The behavior of embodied AI models depends heavily on how closely the factory’s digital twin reflects physical assembly variances. Dr. Lee emphasizes the need for a closed-loop feedback system between shop-floor sensors and AI foundation-model training pipelines, continuously updating simulation parameters based on empirical plant distributions to maintain Sim-to-Real alignment.
Uncertainty quantification can help separate physical variance from sensor noise in the calibration loop and support training-pipeline diagnosis. Dr. Lee also highlights an Edge-to-Cloud governance platform that allows the runtime sensor behavior of every finished vehicle or robot to be traced back to lot-level silicon, component calibration, and environmental conditions at the moment of production. This strengthens root-cause analysis for field failures.
Advice for Young Researchers and Students
- Bridge Physics with Data-Driven Cloud-Edge Architectures
Physics-informed and explainable AI enhances causality. Dr. Lee notes that resilient breakthroughs often emerge at the intersection of domain physics and data science, such as Physics-Informed Neural Networks (PINNs).
He also encourages researchers to pair this methodology with modern distributed architectures: understand how to deploy lightweight, low-latency inference at the edge while orchestrating heavy model training and digital-twin governance in the cloud.
- Ground Research in Industry-University Collaboration
Seek out research initiatives that directly address industrial shop-floor bottlenecks. Clean theoretical datasets rarely capture the messy, sparse, and asynchronous realities of production environments.
Working closely with industry partners exposes researchers to genuine edge cases, transforming theoretical algorithms into robust, production-grade solutions that generate real economic and operational value.
- Actively Cultivate Interdisciplinary Networks
Connect early and consistently with professional societies such as IEEE RAS, open-source communities, and cross-disciplinary peers. Complex engineering domains – from embodied AI to smart manufacturing – require diverse expertise spanning mechanical hardware, advanced materials, computer science, and information management.
Engaging in conferences, joint workshops, and active technical discourse builds collaborative pipelines that can define a researcher’s career trajectory.
| “The quality of your networks defines the quality of your academic life.” |
IEEE CASE 2026 thanks Dr. Chia-Yen Lee, Senior Editor of IEEE T-ASE, for sharing his research insights and perspectives with the robotics and automation community, and Dr. Chin-Yi Lin, IEEE CASE 2026 Science Communication Ambassador, for conducting and preparing this interview.